Specifications
Product Specification
Basic
ModelG5-13A18D-S01
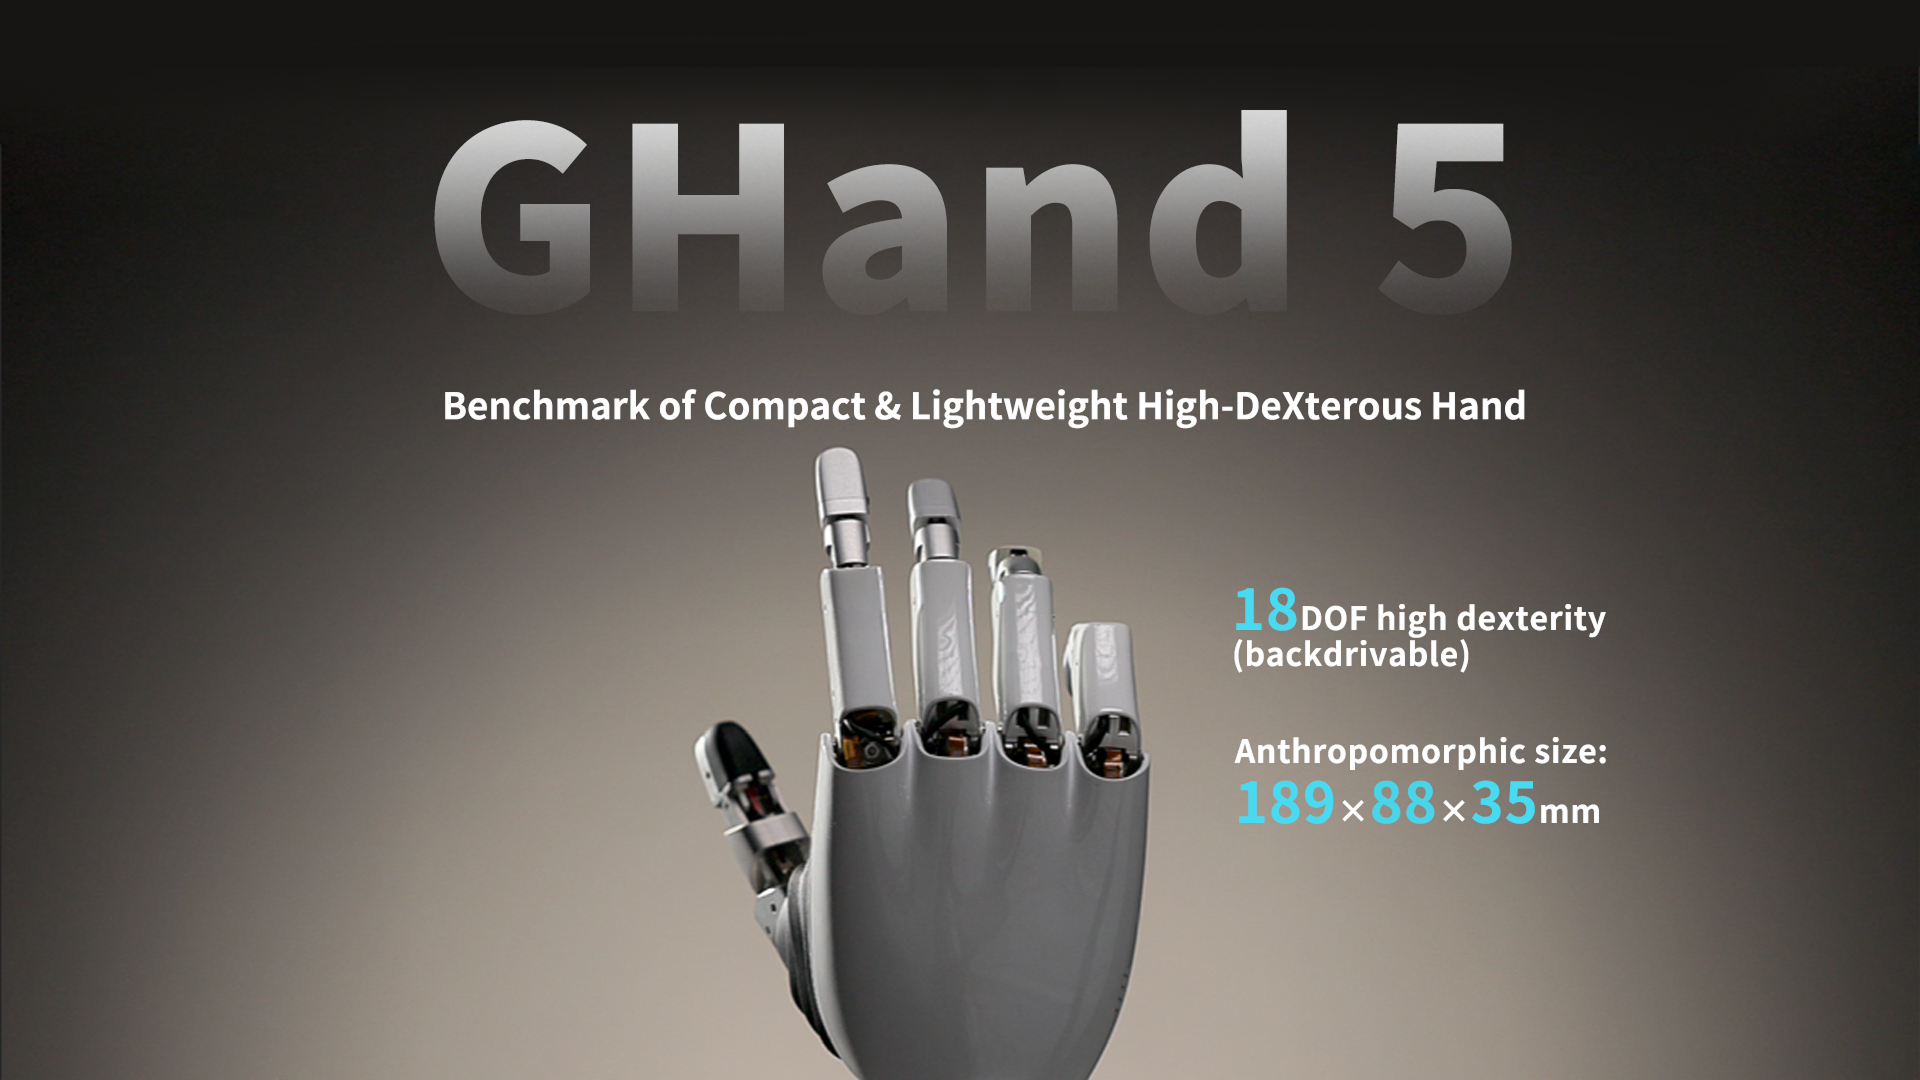
Dimensions189 mm × 88 mm × 35 mm
Weight760 g
Degrees of freedom18 (13 active + 5 passive)
DOF allocationThumb: 4 active + 1 passive
Index: 3 active + 1 passive
Middle: 2 active + 1 passive
Ring: 2 active + 1 passive
Little: 2 active + 1 passive
Motor typeBrushless coreless motor
StructureRigid-soft-compliant coupled
Max grip force (whole hand)60 N
Max fingertip force (single finger)38 N
Max thumb fingertip force27 N
Closing time0.6 s
Repeatability0.2 mm
Sensing
SensorsTactile sensor, temperature sensor, position sensor
Tactile arrays5 arrays (162 pressure points in total), on the fingertips of all five fingers
Tactile array resolution31 points on each of the four fingers, 38 points on the thumb
Tactile sensingThree-axis force
Tactile rangeNormal force 20 N; shear force 10 N
Fault detectionOver-current, stall, over-voltage, under-voltage, over-temperature and interference detection
Electrical
Operating voltageDC 24 V – 60 V
Standby current0.2 A @ 48 V
Max current2 A @ 48 V
CommunicationEtherCAT / CAN FD / RS485
SDK languagesPython / C++ / ROS2
Software featuresPosition, velocity and torque control; motion sequences; GUI control; tactile force control; virtual simulation; gesture control
Control modesTriple-loop PID control; velocity, torque, position and hybrid force-position control; adaptive grasping
Operating systemsWindows / Linux / macOS
Ecosystem compatibilityCompatible with mainstream humanoid robots, robotic arms, data-collection gloves and VR headsets;
supported simulators: Isaac Sim, MuJoCo, Gazebo
Reliability
Operating temperature-20 °C – 50 °C
Motor lifetime> 2000 h (2 million cycles)
Full-hand open/close (no load)≥ 1,000,000 cycles